讲座题目 | Road-Constrained Carrier-Drone Inspection Scheduling with Continuous En-Route Operations | ||
主讲人 (单位) | 李纪柳(西北工业大学) | 主持人 (单位) | 金子亮(国产探花 ) |
讲座时间 | 2026年12月8日10点 | 讲座地点 | 人文社科综合楼310 |
主讲人简介 |
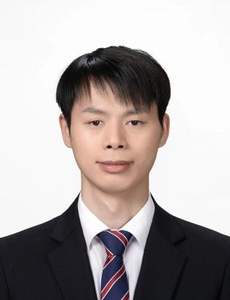
李纪柳,博士,西北工业大学教授、博士生导师,陕西省青年高层次引进人才。博士毕业于华中科技大学,曾赴香港理工大学开展访问交流。聚焦精确算法、鲁棒优化、强化学习等优化方法,致力于物流系统优化与复杂网络规划研究。主持国家自然科学基金项目2项,获陕西省第十七届哲学社会科学优秀成果一等奖,入选管理科学与工程学会 “博士学位论文支撑计划”。研究成果发表于IJOC、TS、TR-B/E、EJOR、Omega等国际顶级及权威期刊。 | ||
讲座内容摘要 | This report explores a road-constrained carrier-drone inspection problem in which carriers follow prescribed road paths while drones take off from and land on the moving carriers at continuous locations. The problem jointly determines path activation, target allocation and sequencing, takeoff and landing arcs, and continuous rendezvous locations to minimize total completion time. Unlike the carrier-vehicle traveling salesman problem (CVTSP) in an unconstrained Euclidean plane, the road topology adds discrete path and arc choices while retaining continuous geometric coordination and second-order conic constraints. We formulate this problem as a mixed-integer second-order conic programming (MISOCP) and derive projectioninduced service intervals, safe variable fixing rules, strengthened lower bounds, and conic reformulations to enhance the model. We then develop a logic-based Benders decomposition (LBBD) method that separates sequencing decisions from path-specific drone operations and uses analytical cuts based on travel-time bounds. Computational experiments based on real-world wind farm data demonstrate the effectiveness of the proposed model enhancements and the LBBD approach. Sensitivity analyses further show that faster carrier and longer drone endurance have diminishing returns when carrier waiting becomes the dominant synchronization cost, and that continuous rendezvous decisions reduce this waiting relative to discretized alternatives. | ||